James Farmer — Mechanical Engineer & Robotics Researcher

Mechanical · Dexterous Manipulation · Prosthetics

About

Dexterous Manipulation
With Human-centric Design

I'm James, a high school student at the Peddie School in Hightstown, New Jersey. I'm highly interested in robotics, with a focus on mechanical design and dexterous manipulation.

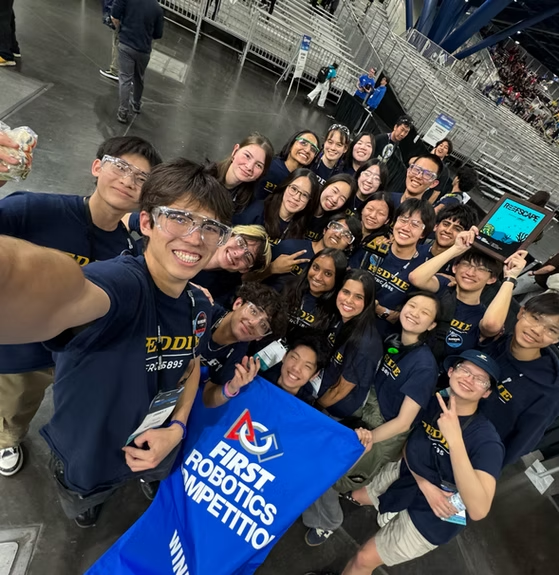
Currently, I'm a lead designer on Peddie Robotics, our championship-winning FIRST Robotics Competition (FRC) team. Previously, I was a mechanical engineering intern at RobotEra and a researcher with the NJ Governor's School of Engineering & Technology.

James Farmer — work in the lab
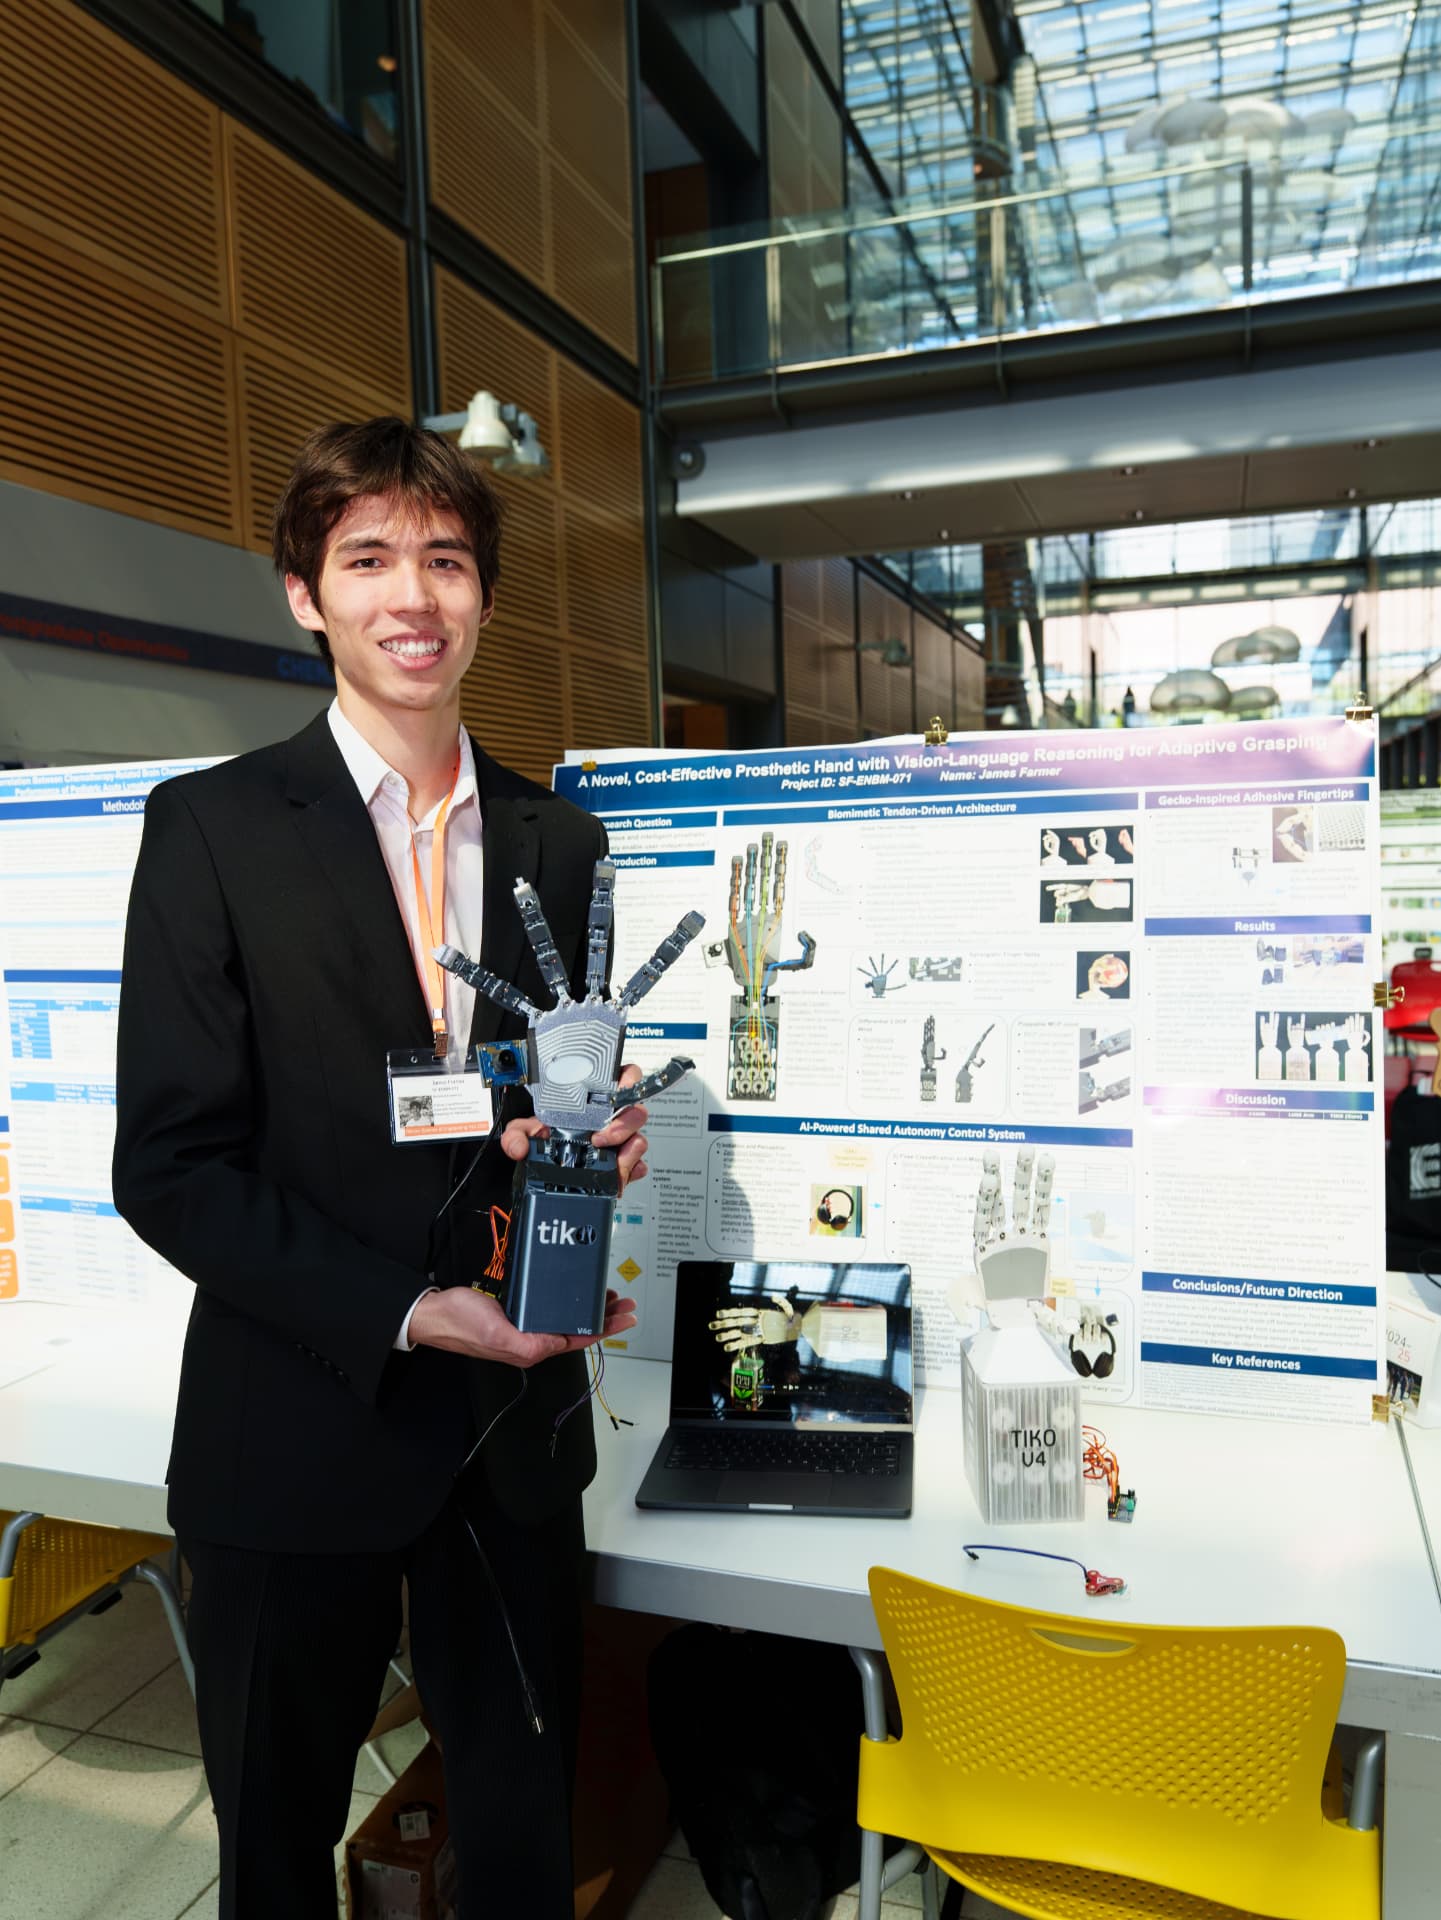
James Farmer presenting the TIKO prosthetic hand research poster
01

Selected Projects

Ordered by significance
Forearm4× smallerWrist+2 DOFAward1st Biomed

Designer

TIKO V4c is the prosthetic-focused evolution of the TIKO platform. Mechanically, its primary innovation is weight and size reduction: smaller motors and tighter packaging shrink the forearm to roughly one-quarter the volume of TIKO V4 while incorporating two additional motors. A new differential wrist adds two degrees of freedom, enabling the combined flexion/extension and pronation/supination motions critical to advanced prosthetic function.

On the software side, V4c introduces the TIKO control system, which addresses a key dichotomy in prosthetics: a high-DOF mechanical hand is only as useful as the control layer driving it. Instead of manual grasp selection, TIKO uses a point-and-grasp strategy. The user places their hand in front of an object and pulses their muscle once for grasp mode or twice for tool mode (illustrated by the headphone example). A second pulse near the object triggers closure, and a final pulse resets the grasp. Because the pipeline is built on open-vocabulary object detection, users can add and customize grasps indefinitely without losing the dexterity of the underlying mechanical body.

Awards: 1st Place in Biomedical Engineering, 2026 Mercer Science & Engineering Fair; Diamond Award; Blue Ocean Award.

OnshapeDifferential WristEMGOpen-Vocabulary Detection
Fitting2 photosMeasurements15Attachments12
Open-source prosthetics fitted from two photos, with 12 activity-specific attachments.

Founder

I founded LimbKit, a nonprofit that designs low-cost, accessible prosthetics.

LimbKit starts with the fitting. A prosthetic is only as good as its fit, but people with limb differences in developing countries often can’t reach the clinical support a custom fitting normally requires. Our process replaces that visit with two photos of the limb, from which we derive 15 measurements to generate a custom design.

Apart from the foam padding and Velcro straps, the prosthetic is fully 3D-printed, so anyone with a basic consumer 3D printer can make one. Most of the body is rigid PETG or PLA, with a flexible TPU spine running along its length so it can expand and contract as the user’s limb changes size through the day.

Conventional prosthetics imitate the human hand, but five fingers are hard to control intuitively and handle only a narrow range of real-world tasks. LimbKit instead uses a set of 12 attachments that swap on and off quickly, each built for a specific activity. Users can play the violin, eat with cutlery, or write with a pen without thinking about where the fingers land or which grip to trigger.
3D PrintingPETG / PLATPUModular Design
Materials2ControlVisionVenueMIT URTC
A vision-guided gripper that chooses between gecko adhesive and polyurethane pads.

Mechanical Designer & Researcher

This project started as a follow-up to my earlier work on gecko-inspired compliant grippers. With six other students, I built a gripper that swaps between gecko adhesive pads and polyurethane pads depending on what it is picking up. The gecko pads beat silicone on almost every object we tried, so I molded a custom flexible polyurethane instead, which held rough objects far better than gecko could.

A camera and a pair of LEDs feed a 2D FFT that estimates surface roughness, while the same image predicts how much of the pad will actually engage. Those measurements, plus mass and a semantic description of the surface, let a vision-language model search prior grasps and predict the force needed. Across 44 objects tested with both pads, a single roughness threshold picked the lower-force configuration 86.4% of the time. On unseen objects, retrieval-grounded prediction reached 0.205 N mean absolute error, a 91% reduction from a zero-shot baseline. I worked on this with a team at the NJ Governor's School of Engineering and Technology.

Gecko AdhesivePolyurethaneComputer VisionVision-Language Model
Intake25 BPSVersions5AwardCreativity
Championship-winning robot: double turret + 25 BPS intake.

Mechanical Co-lead & Intake Design Lead

In the 2026 FRC season, I co-led the mechanical team — driving robot archetype and design strategy while contributing to robot mechanisms. I enjoyed assembling and maintaining our signature turret, an ambitious system pairing two shooters with full 360° rotation.

As intake design lead, my team rapidly iterated through five competition-ready versions. Each release pushed balls-per-second (BPS) higher, with the final design hitting 25 BPS. Rigidity drove the architecture: the first version, a rigid slapdown intake, was abandoned for weight; the second, a flexible four-bar, folded on impact. As match aggression scaled with level of play, our final sliding intake used a curved rack-and-pinion deployment with 1/2" polycarbonate arms — combining the impact-tolerance of the four-bar with the rigidity of the slapdown. Over spring break, I led a sub-team that tested 28 unique compression geometries to lock in the BPS optimum.

Awards: FRC World Championship Creativity Award.

OnshapeRack & PinionPolycarbonateRapid Prototyping
Study2×2VenueRoboSoft '26StatusPublished
Paper submitted to RoboSoft 2026 on compliant gecko adhesion.

Researcher

This project investigates the macro-micro coupling between compliant backings and gecko-inspired adhesives to improve robotic grasping on complex geometries. The resulting paper, Maximizing van der Waals Contact in Gecko-Inspired Grippers for Complex Object Geometries via Compliant Backing, was submitted to RoboSoft 2026. Using a controlled 2×2 design, I evaluated gecko adhesives versus silicone pads on rigid (PLA) and compliant (TPU) backings to isolate the effect of macro-conformity on adhesion. The compliant Gecko+TPU configuration significantly reduced required normal preload on smooth, curved objects by maximizing real van der Waals contact area. I also developed and validated a reduced-order model predicting a critical performance crossover, establishing clear design guidelines: compliant gecko grippers are optimal for smooth, curved surfaces, while friction-based methods remain superior for rougher ones.

Gecko AdhesiveTPUPLAForce TestingModeling
Prototypes18Pieces2ResultDivision Win
One compact mechanism, two game pieces — 18 prototypes deep.

Scoring Mechanism Design Lead

As scoring mechanism subteam design lead, I led development of a dual-purpose end effector for handling both CORAL and ALGAE in the 2025 FRC game, requiring a single compact mechanism that could switch tasks without added fragility or cycle-time cost. A belt-driven, four-roller architecture with guiding side flanges centers and extracts CORAL from the intake, then stows and actively ejects it for scoring, with real-time sensor feedback to confirm capture and prevent jams. For ALGAE, a paired compliant-wheel "claw" pivots into the reef, rolls the piece deeper into the grip, and halts on sensor detection; reversing the wheels enables fast, controlled ejection for barge scoring. Stacking the ALGAE system above the CORAL path and tuning geometry (~35° CORAL angle) optimized scoring alignment while disciplining mass and packaging. The design converged after 18 prototypes, followed by four refined competition builds balancing reliability, compactness, and match durability.

Awards: FIRST Robotics World Championship — Milstein Division Winner & Einstein Field Qualifier (2025).

CADBelt DriveSensor FeedbackPrototyping
Program3 daysLocationGansuToolsBasic
A three-day mechatronics curriculum taught in Gansu, China.

Instructor & Designer

This project, my first robotic hand, was intentionally designed for easy assembly with basic tools. I used it as the foundation of a three-day teaching program in Gansu, where students progressed through a structured curriculum introducing core mechanism-design principles, beginning with simple pendant design. Students then assembled the hand from provided parts, learned foundational wiring through basic LED circuits, and integrated the electronics. The program concluded with programming the hand for basic movements and rock-paper-scissors competitions — giving students a tangible way to validate their mechanical, electrical, and software work.

OnshapeArduinoServosCurriculum
02

Publications

Peer-reviewed & poster
2026CO-AUTHOR

A Dual-Material Robotic Gripping System with Experience-Grounded Force Prediction

IEEE MIT Undergraduate Research Technology Conference 2026

A dual-material gripper pairing rigid and compliant contact surfaces, with force prediction grounded in prior interaction experience for more reliable grasping.

2026Co-author

Maximizing van der Waals Contact in Gecko-Inspired Grippers for Complex Object Geometries via Compliant Backing

IEEE RoboSoft 2026

A controlled 2×2 study of gecko adhesives vs. silicone pads on rigid and compliant backings, with a reduced-order model predicting a performance crossover for smooth curved objects.

03

Resume & Awards

As of May 2026

Education

  • The Peddie School

    2023 – 2027

    Hightstown, NJ · Coursework in Multivariable Calculus, AP Physics C, AP Computer Science, and Engineering

HIGHLIGHTED EXPERIENCE

  • Mechanical Co-lead 

    Peddie Robotics (FRC 5895)

    2024 – Present

    Championship-winning FRC team

  • Researcher, Gecko-Inspired Grippers

    Research — Dr. Arsen Abdulali & Dr. Ibragim Atadjanov

    2025

    Paper accepted to RoboSoft 2026

  • Mechanical Engineering Intern

    RobotEra

    2024

  • Instructor & Curriculum Designer

    Gansu Engineering Teaching Program

    2024

Awards & Honors

  • Milstein Division Winner & Einstein Field Qualifier

    FIRST Robotics Competition — World Championship

    2025

  • 1st Place, Biomedical Engineering

    Mercer County Science & Engineering Fair

    2026

  • Semifinalist & Ambassador

    Diamond Challenge

    2026

  • Division Finalist

    FIRST Robotics Competition — World Championship

    2024

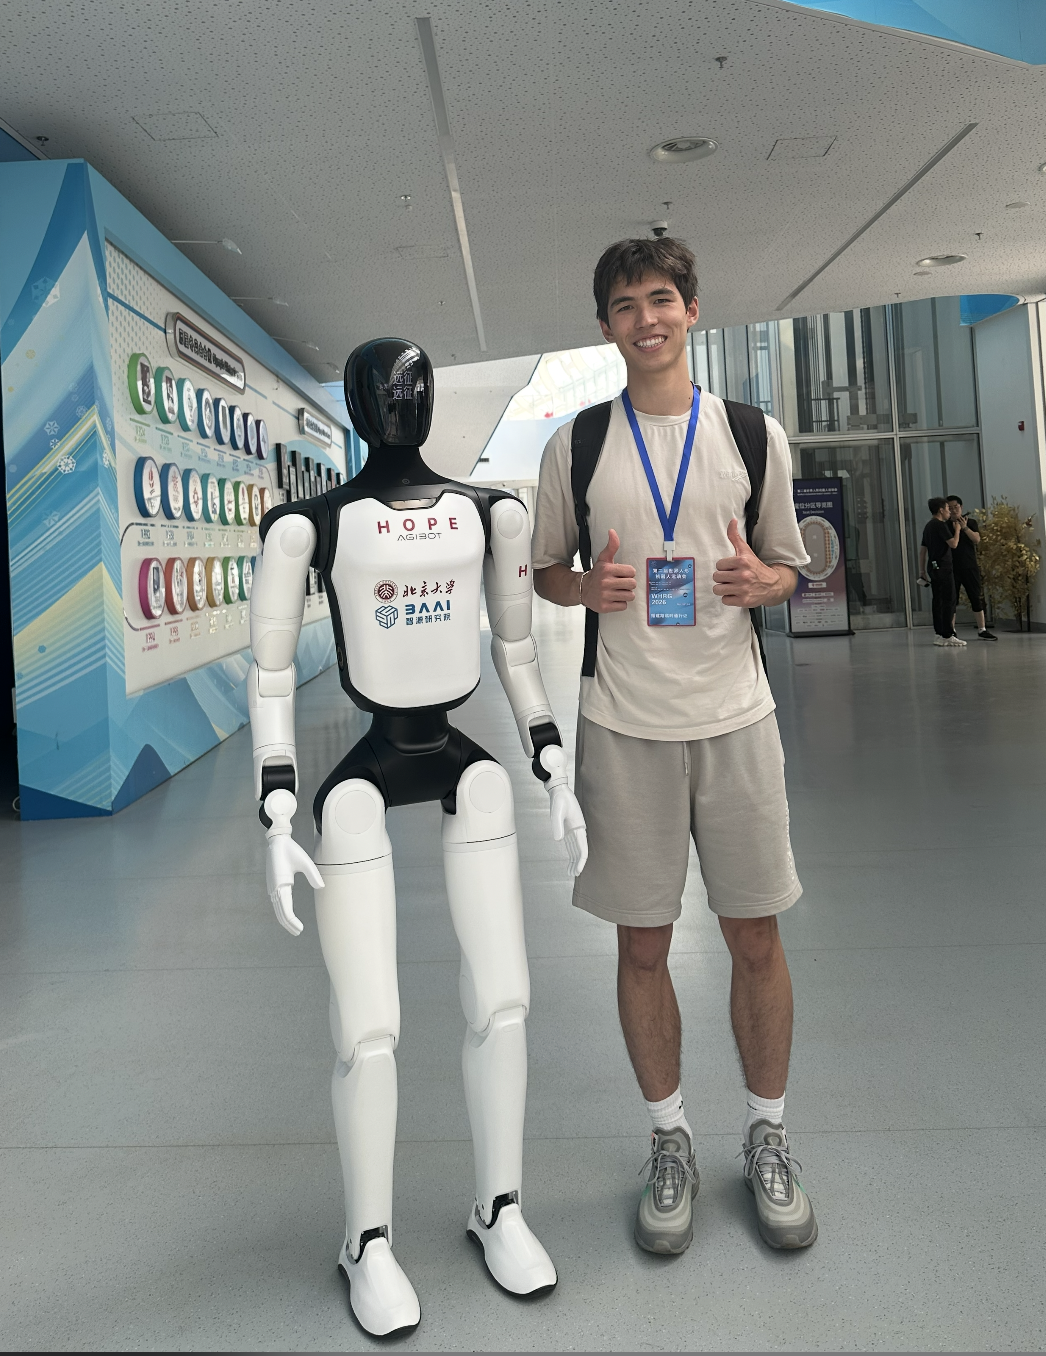
James Farmer with a humanoid robot
James Farmer with the outdoors club
James Farmer with the Peddie soccer team
04

Contact

LocationPrinceton, NJ